Can the AC motor controller with PID control simplify the regulation circuit of the VFD?
Industrial process control often depends on more than motor speed. Pumps, fans, pressure systems, and flow equipment may need the drive to react to changes in pressure, temperature, level, or flow. A suitable ac motor controller can simplify this work when the control structure matches the process.
The main issue is coordination. Motor response, sensor feedback, PID settings, and mechanical delay all affect loop behavior. When these parts are configured together, engineers can reduce unnecessary control layers and make commissioning easier.
Why Regulating Loops Become Difficult
A regulating loop compares a target value with a measured value. The controller then changes motor speed to reduce the difference. Real systems include load changes, response delays, and unstable feedback. Poor settings can cause hunting, overshoot, or slow recovery.
The mechanical load also matters. A fan behaves differently from a pump working against changing pressure. If acceleration is too fast, the process can overshoot. If it is too slow, the system may take too long to return to the target.
Sensor quality affects the loop as well. Pressure transmitters, flow sensors, and temperature signals should remain stable through the working range. A noisy signal can make the drive react too often. Signal scaling and filtering should therefore be checked before PID gains are adjusted.
How Motor Control Supports PID Regulation
An ac motor controller can simplify regulation when speed control, feedback processing, and protection functions operate within one platform. Engineers can then adjust motor response and process feedback without adding separate devices for each task.
This is where a vector control inverter can be useful. Vector control gives the drive closer control over motor torque and speed than simple frequency adjustment. Under changing loads, this can make motor response more predictable before PID tuning starts.
PID settings still need to match the mechanical system. Proportional gain determines how strongly the drive reacts to error. Integral action corrects lasting deviation. Derivative action may help in selected processes. The balance depends on inertia, load change, and process delay.
What Built-In PID Functions Can Change
Integrated PID functions can reduce extra control hardware in some installations. The drive can receive a setpoint, compare it with feedback, and adjust output frequency according to the error. This can also simplify wiring between separate control devices.
Multiple PID parameter groups can help when one machine operates under different conditions. Startup, low-load operation, and higher demand may require different response settings. Feedback-loss detection is also practical because it helps maintenance staff separate a sensor problem from a motor or mechanical problem.
Practical Steps Before Tuning
Before tuning begins, engineers should confirm motor nameplate data, sensor range, feedback direction, and acceleration time. Incorrect motor data can affect speed and torque response, while incorrect feedback direction can make the loop move away from the setpoint.
A practical method is to begin with conservative gains. Engineers can raise proportional gain gradually and watch how quickly the process reacts. Integral action can then remove steady deviation without causing repeated oscillation. Changes should be made one step at a time so each response remains easier to interpret.
Testing at several load points is useful because loop behavior can change when flow or pressure changes quickly.
Drive Application in a Real Operating Scenario
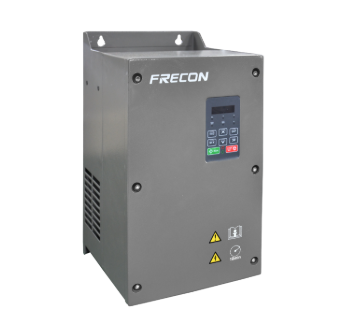
For projects that need motor control and process regulation, FRECON offers the FR380 Series High Performance vector control inverter. The series includes a built-in smart PID function, allowing speed control and closed-loop regulation to operate through the same drive.
The FR380 includes two groups of PID parameters. They can switch according to deviation, DI terminal status, or frequency conditions. The drive also supports different given-value and feedback-source selections, which helps engineers match field signals to the control loop.
The series also includes PID feedback-loss detection, plus dormancy and wake-up functions that can switch according to frequency and pressure conditions. These functions suit systems where the motor does not need to run continuously.
When Integrated Control Becomes Simpler
A vfd with pid control does not remove the need for commissioning. Engineers still need to confirm motor parameters, sensor behavior, setpoint logic, acceleration time, and PID gains. Its value is that several related control tasks can be handled through one drive platform.
The benefit is clearer when motor speed directly affects a measurable process variable. Constant-pressure water systems are one example. When demand changes, the drive can adjust pump speed from pressure feedback instead of operating at one fixed frequency.
Similar logic can apply to airflow, liquid level, and some temperature-related processes. PID parameters should be tuned around actual process behavior rather than copied from unrelated applications.
Building a More Manageable Loop
Integrated control can make regulating loops easier when the drive functions match the process. Engineers should review feedback quality, load type, response time, switching conditions, and fault handling before deciding how much control logic should remain inside the drive.
FRECON provides one example of how motor regulation and PID functions can be combined in a single platform. Still, the quality of the final loop depends on correct setup, stable feedback, and careful tuning rather than on the drive function alone.
A manageable loop is easier to maintain over time. Clear feedback paths, documented switching conditions, and sensible alarm logic help technicians understand why motor speed changes and where to look when process values begin to drift.